MIT BWSI CubeSat Challenge Award-Winning Student Engineering Team Designing & Building NASA Exploration Rovers
NASA HERC Challenge Overview
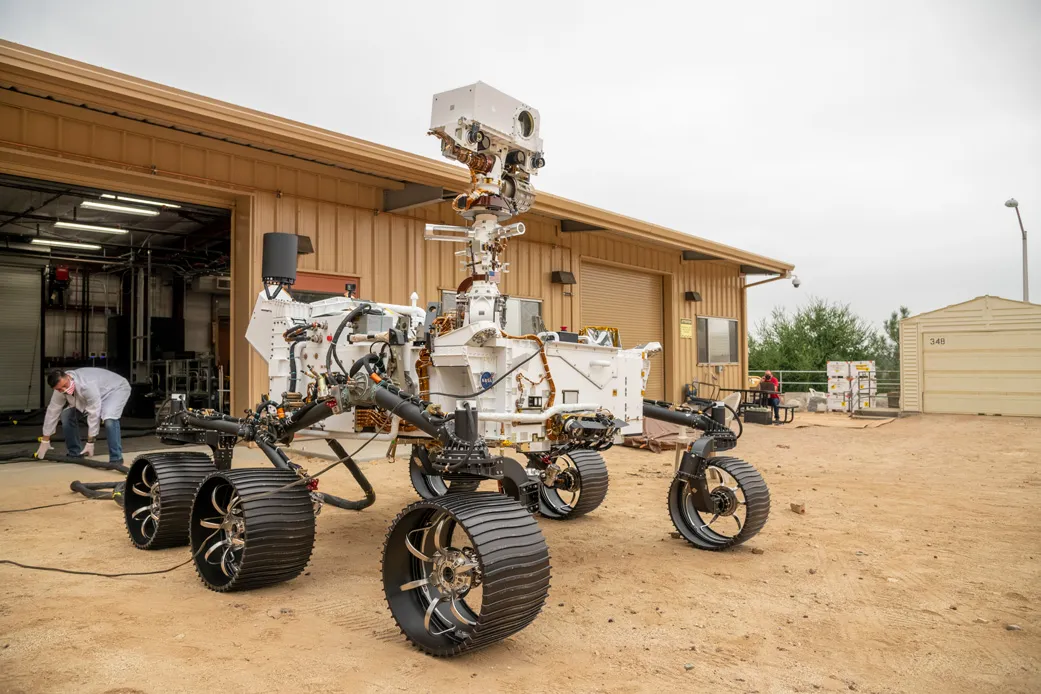
"HERC is a nine-month long challenge that tasks student teams to design and build human-powered or remote-controlled rovers capable of traversing challenging lunar terrain while completing mission tasks. It is a hands-on, research-based, engineering activity and culminates each year with a final excursion event in Huntsville, Alabama, home of NASA's Marshall Space Flight Center. The activity offers multiple challenges, reaching a broad audience of colleges and universities as well as middle and high school aged students across the world." — NASA
Rover Engineering
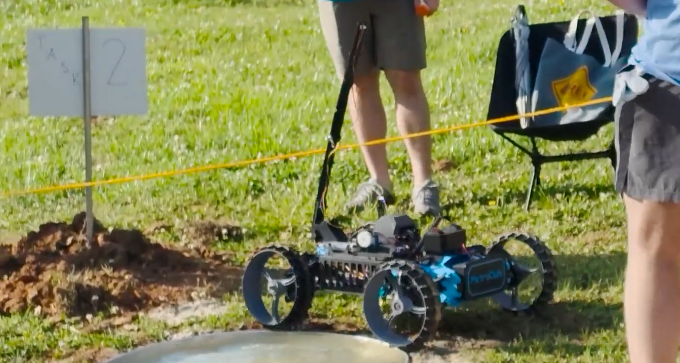
We design, fabricate, and test a remote-controlled rover using various engineering solutions, such as CAD modeling, 3D printing, and CNC machining.
Terrain Navigation
We utilize various strategies, such as weight management and debris management to traverse rough terrain. We are unique in our use of treads on our rover, which allows us to traverse rough terrain and inclines with ease.
Science Tasks
After the rover arrives at the task site, we perform simulated science tasks for the mission, including measuring distance and identifying objects.
Engineering Subsystems
Students lead design, fabricate, and test specialized rover systems.
Chassis & Frame
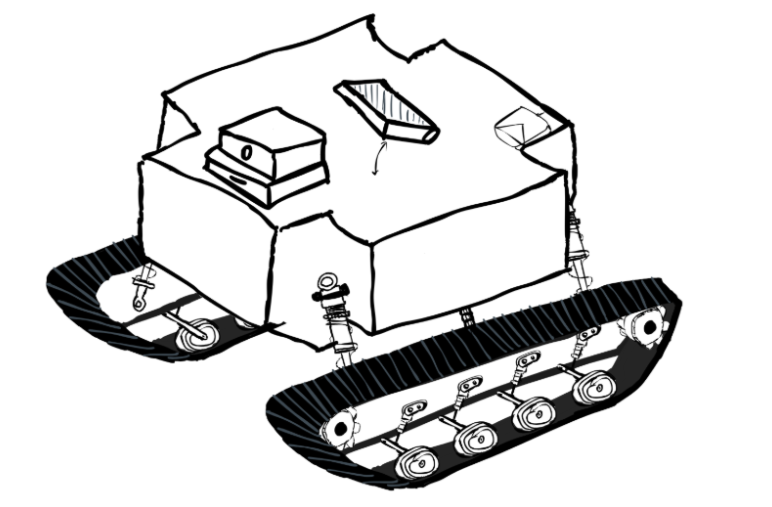
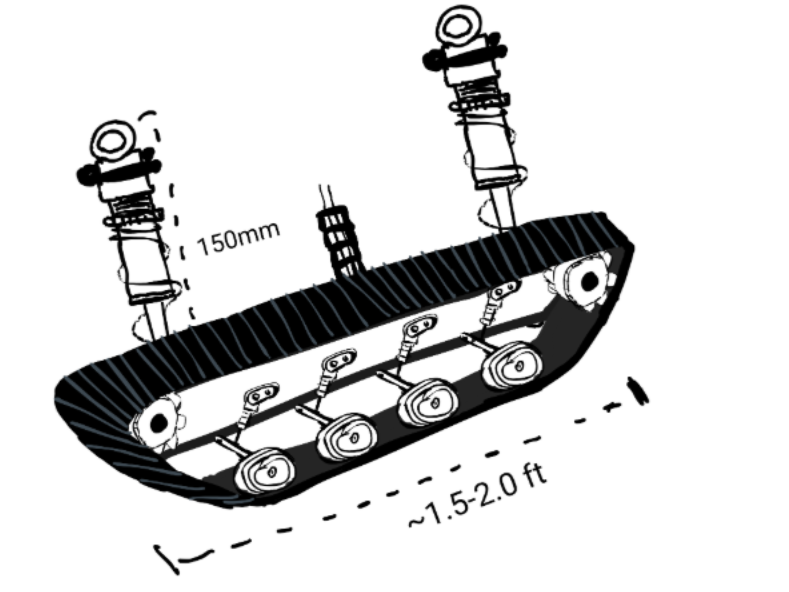
We use lightweight and strong materials like aluminium for the chassis. The chassis is mounted to each tread assembly by two shock absorbers, aiding in suspension.
Drivetrain
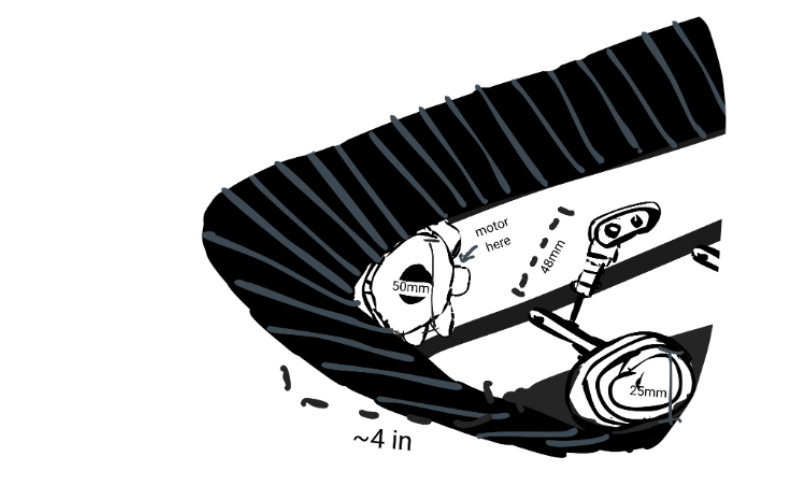
On each tread assembly, we use two sprockets, each driven by its own 12V 10:1 motor, to drive the treads. The bottom of the treads are tensioned by four roller wheels which each have their own shock absorbers.
Electronics & Task Completion
We utilize an electronics system organized around a Raspberry Pi. When radio signals are sent by NASA, we receive them, decode them, and respond accordingly. To do so, we can utilize the gimbal-mounted camera to take pictures, or the ToF sensor to measure distance to a target.
Meet the Team
Student engineers and leaders driving innovation in our rover design.
Karan Krishnan
Student Team Lead
Christos Kyttaris
Student Safety Officer
Alex Shaigorodsky
Hardware Manager
Zirui Wang
Software Manager
Sophie Liu
Pilot
Itay Kedem
Documentation Manager
Hai Dang
Social Media & Outreach Manager
Advisors & Mentors
Aerospace industry experts, flight hardware specialists, and educators guiding Needham Gravity.
Hans Batra
Faculty Advisor
Rohit Viswanathan
Team Mentor
Urban Gillespie
Team Mentor
Greg Jerman
Team Mentor
Donation Tiers
We are looking to raise at least $7,000 to fund our rover design, fabrication, and travel for the NASA HERC 2026-2027 season.
Silver Donor
- Small logo on rover chassis
- Social media acknowledgment
- Logo on team apparel
Diamond Donor
- Prime logo placement on rover
- Featured website & media placement
- Dedicated rover demonstration
- Large logo on team apparel and documentation
Gold Donor
- Medium logo on rover chassis
- Website logo & hyperlink
- Logo on apparel & documentation
While we created these tiers for your convenience, all donation amounts are appreciated.
DonateDonation Instructions:
- Click "Donate" on this website
- Click "Buy Now"
- Specific inputs:
- "Is this donation for something specific? Competition/Event? ": NASA HERC Competition Team from Needham Robotics
- "Club": Select 'Robotics'
- You can donate as a guest if you prefer without signing on.
- You can use credit card or bank account to donate
- The system will auto generate a receipt
Contact Needham Gravity
Have questions, donation inquiries, or interest in supporting our engineering team? Reach out directly to mission control.
Form not working or prefer email? Email us instead
Development Roadmap
Key milestones for NASA HERC 2026-2027 competition.
Season Kickoff & Proposal Submission
Review NASA HERC Handbook rules. Conduct team onboarding webinars, complete proposal drafts, and submit final proposal package to NASA while assigning subsystem teams.
System Architecture & Control Schematics
Receive proposal selection from NASA. Participate in kickoff webinar and finalize initial architecture designs, circuit schematics, and control schemes.
CAD Modeling, DRR & Parts Procurement
Complete full CAD modeling & code drafts. Submit Design Review Report (DRR) & Presentation Slides, and issue hardware procurement orders for chassis & drivetrain.
Manufacturing & Drivetrain Construction
Meet hardware procurement deadlines. Initiate RC control software & rover chassis fabrication while constructing drivetrain tread assemblies, motor drives, and payload hardware.
Autonomy & Subsystem Testing
Integrate core autonomy & task execution code. Conduct extensive pilot driving & autonomous obstacle navigation tests while preparing ORR & ORS drafts.
Full Rover Integration & Code Freeze
Execute full-rover field trials. Finalize travel rosters & team photos, enforce software code freeze, and submit ORR/ORS reports and photos to NASA.
NASA Presentations & Driver Practice
Deliver official NASA Operational Readiness Review presentations. Verify competition-ready rover baseline and commence intensive driver obstacle course practice.
NASA HERC Finals in Huntsville, AL
Complete final system audit & travel packing. Ship rover freight to Huntsville, AL, and compete in the NASA Human Exploration Rover Challenge Finals!